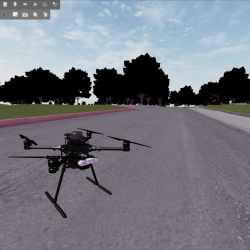
MSc Thesis – UAV Simulation for Semantic Mapping and Human Detection

UAV Simulation for Semantic Mapping and Human Detection Project Overview   The project focuses on the development of an Unmanned Aerial Vehicle (UAV) application designed for manual keyboard-controlled navigation, real-time Simultaneous Localization and Mapping (SLAM) utilizing RTAB-Map (Real-Time Appearance-Based Mapping), and advanced computer vision-based human detection using YOLO. Purpose   By leveraging custom CAD digital modeling, modern Read more about MSc Thesis – UAV Simulation for Semantic Mapping and Human Detection[…]

MSc Thesis – Emotion Recognition from Images using Deep Learning

Emotion Recognition from Images using Deep Learning Project Overview Designed and developed a deep learning image classification pipeline to predict human facial emotions from static grayscale images. Built using Convolutional Neural Networks (CNNs) and fine-tuned on the Kaggle FER-2013 dataset (48×48 pixel facial imagery), the project evaluated transfer learning techniques applied to pre-trained VGG16 and Read more about MSc Thesis – Emotion Recognition from Images using Deep Learning[…]

Pick-and-Place Robotics Task

Home Service Robot Simulation Task Project Overview Designed and developed a two-wheeled Autonomous Mobile Robot (AMR) engineered to act as a home service robot within a simulated indoor building environment. The system autonomously executes pick-and-place tasks on virtual objects. These autonomous systems mirror industrial logistics workflows deployed in automated fulfillment centers. such as Amazon warehouses, Read more about Pick-and-Place Robotics Task[…]