Project Overview
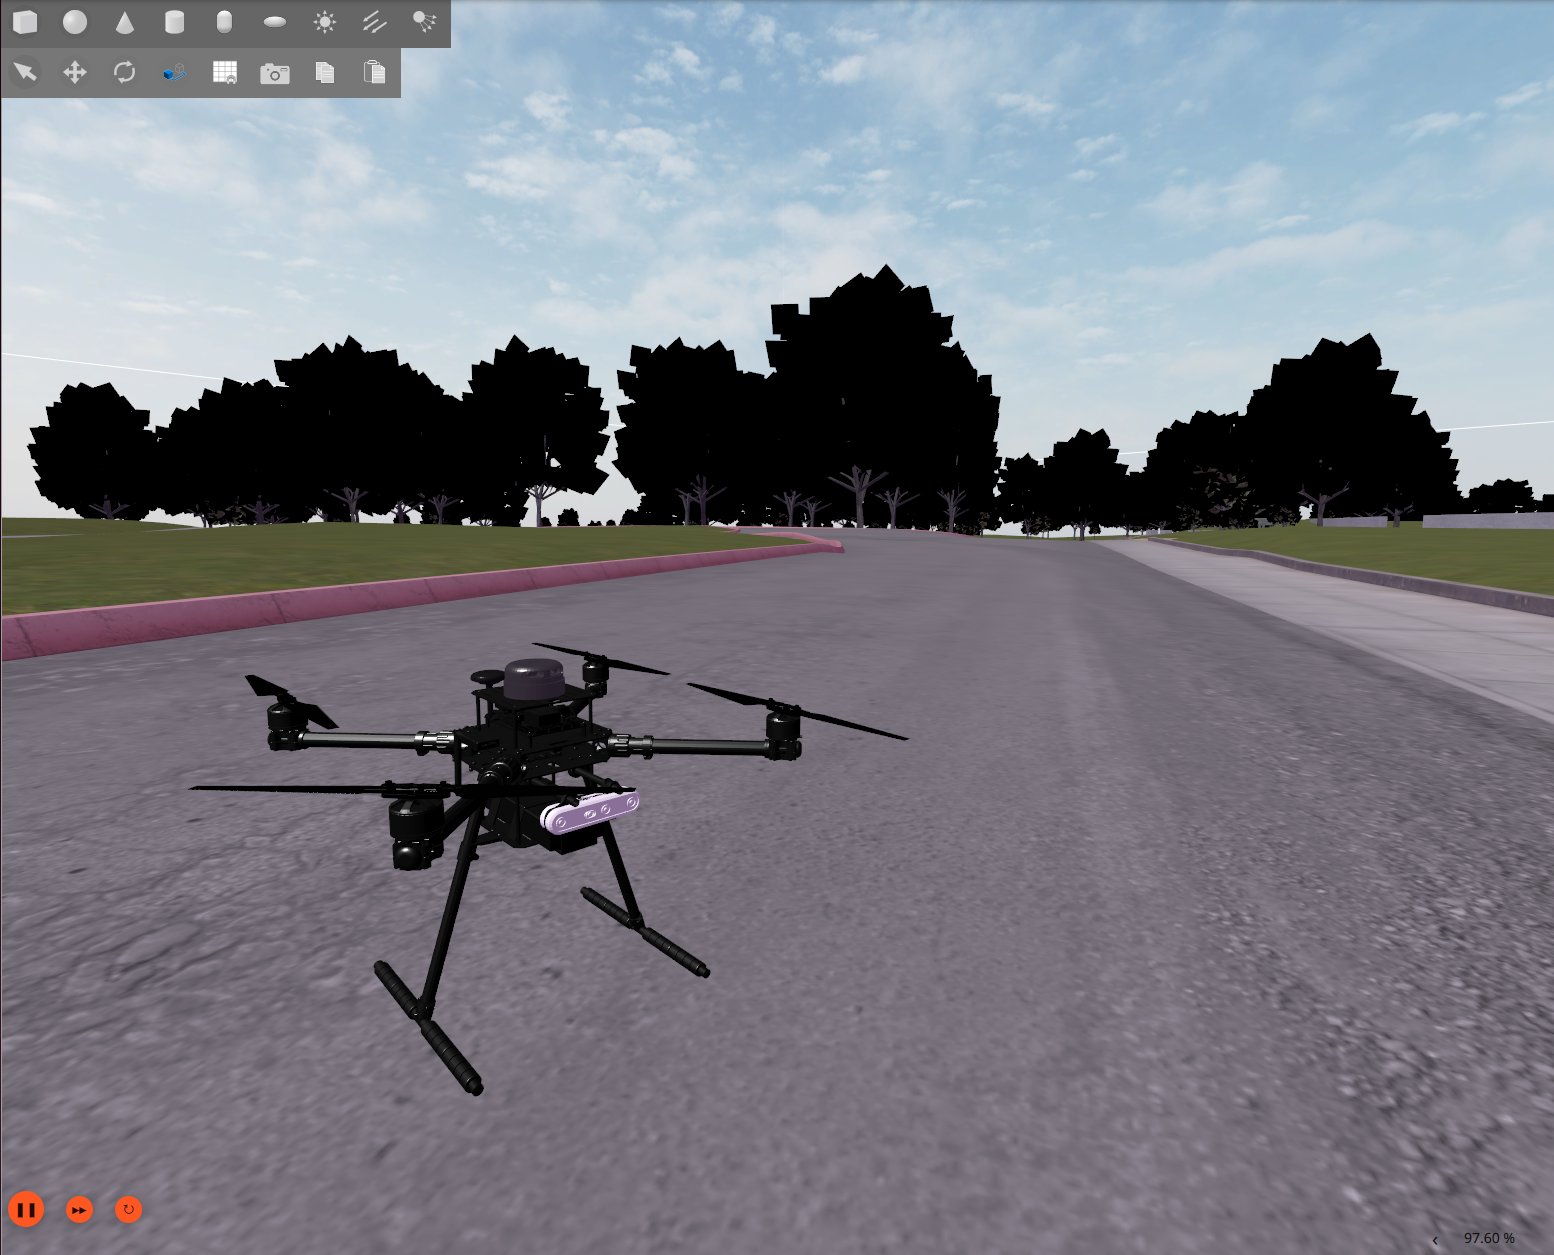
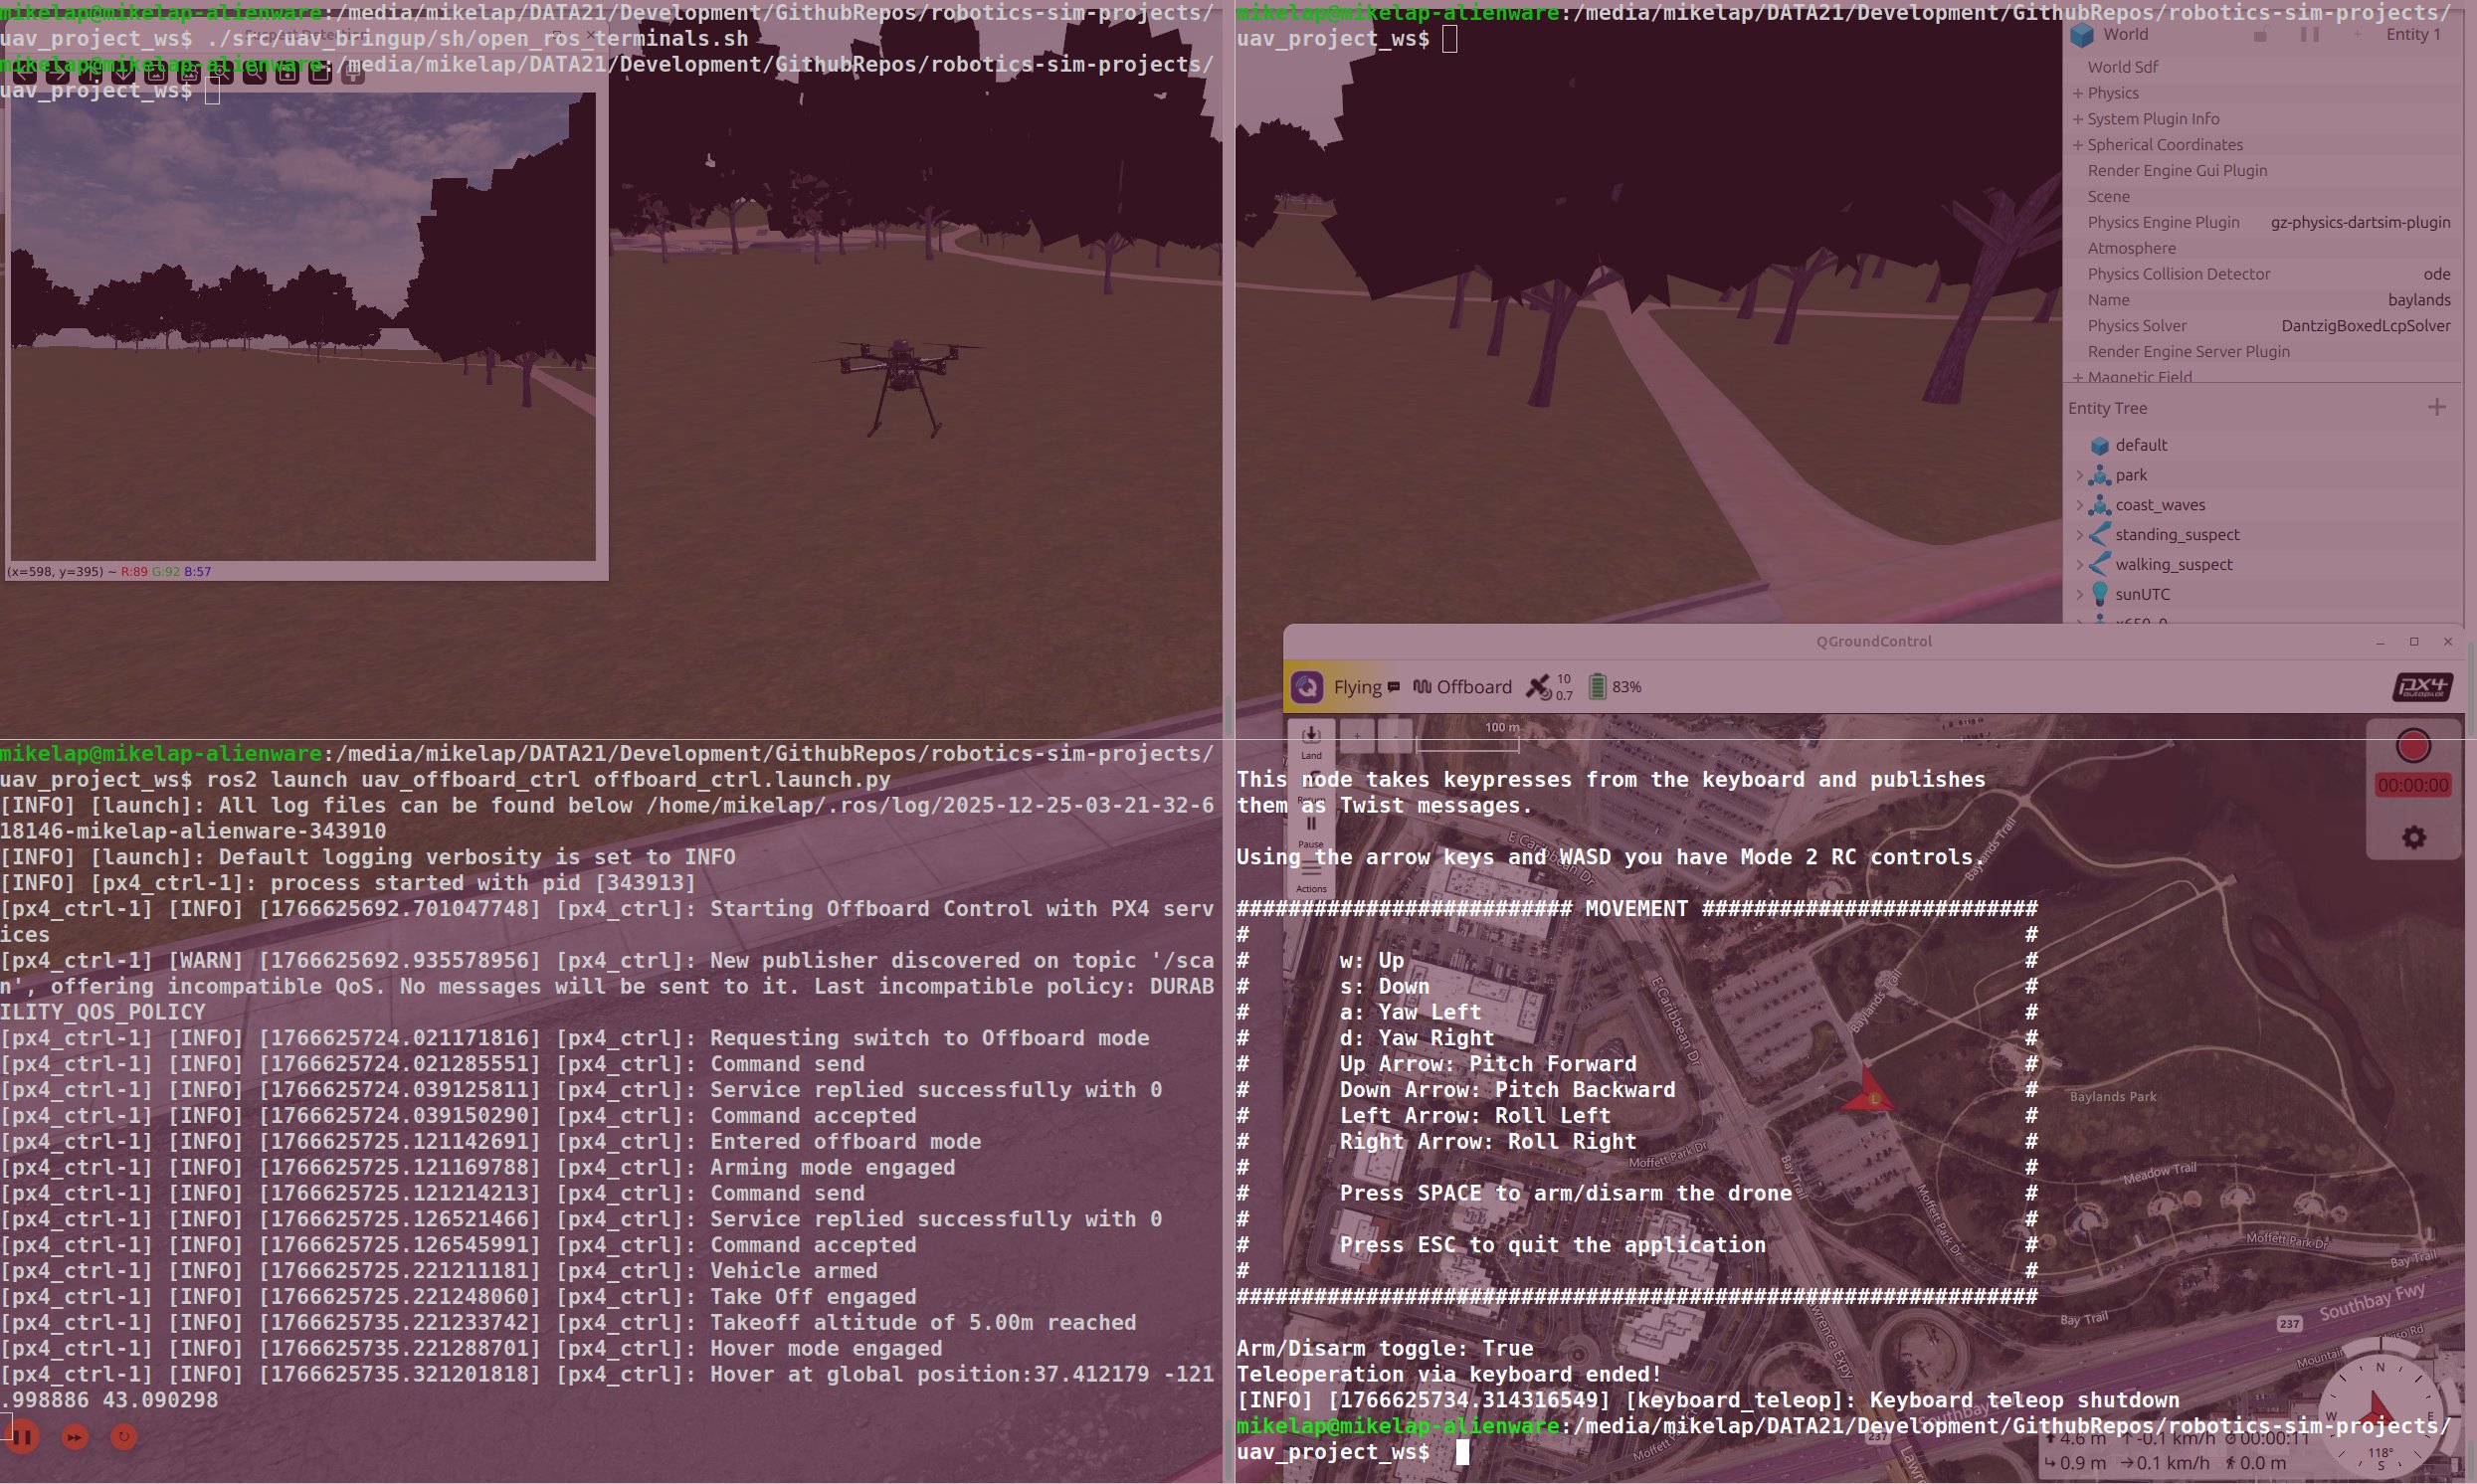
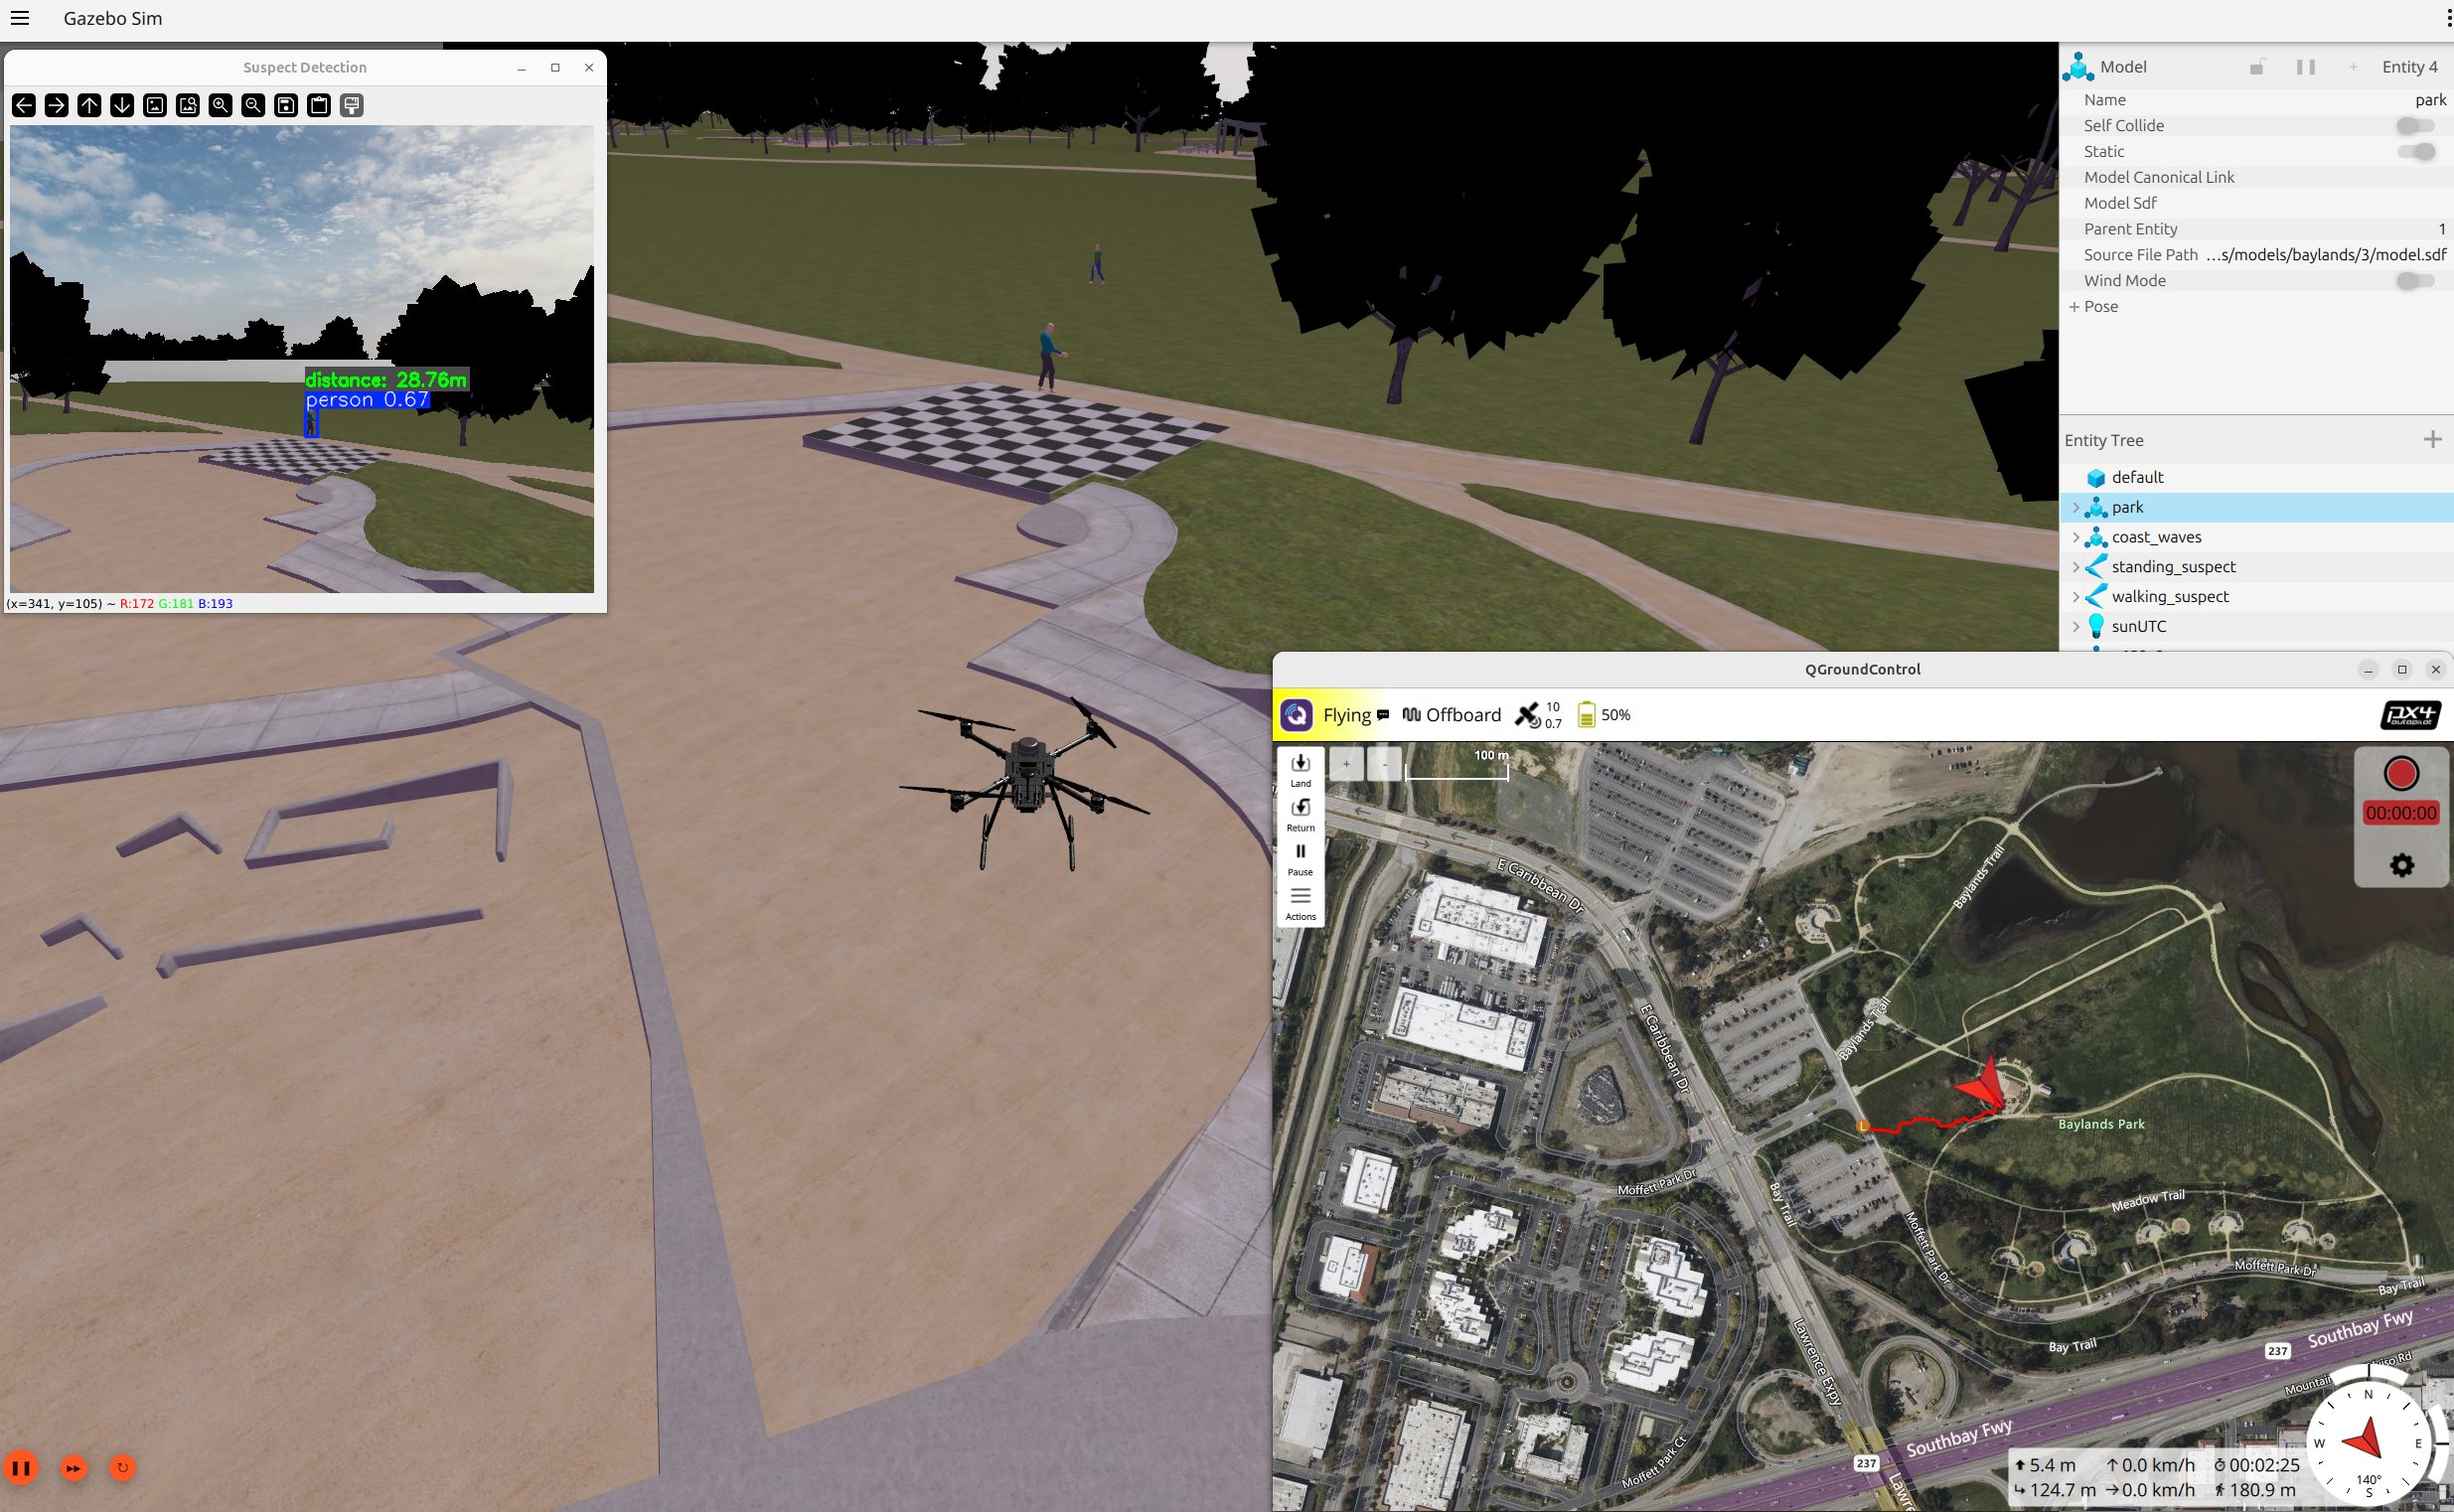
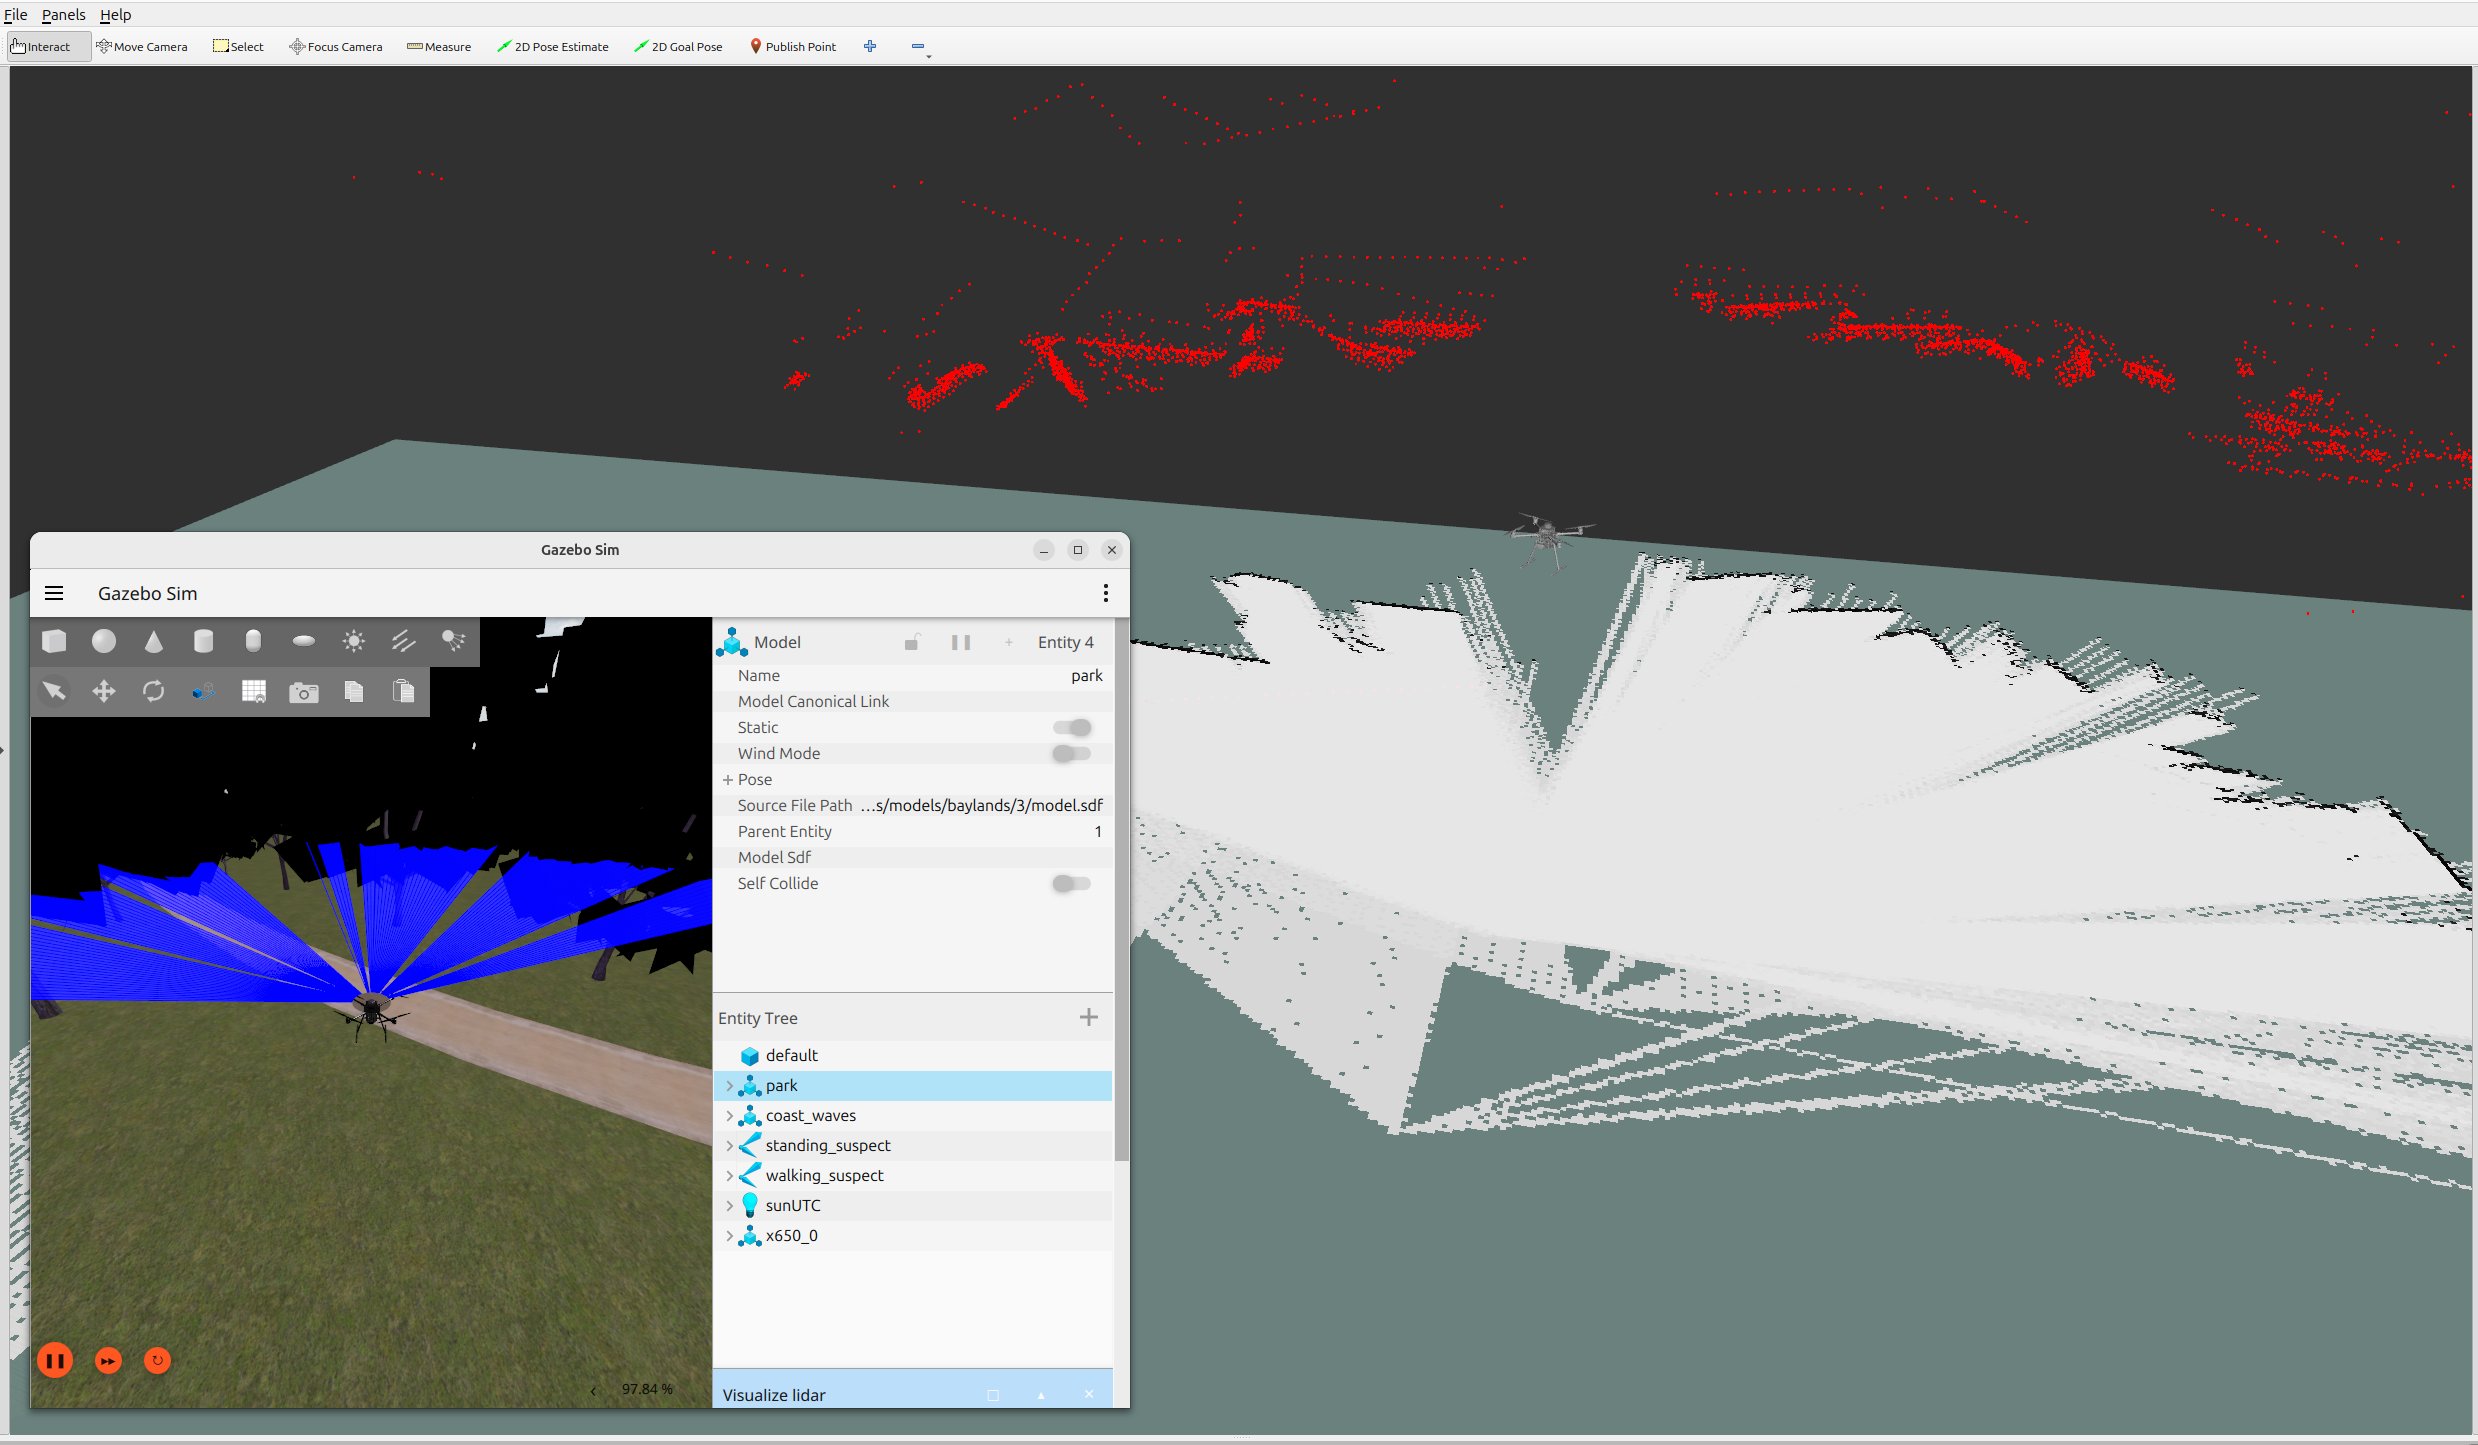
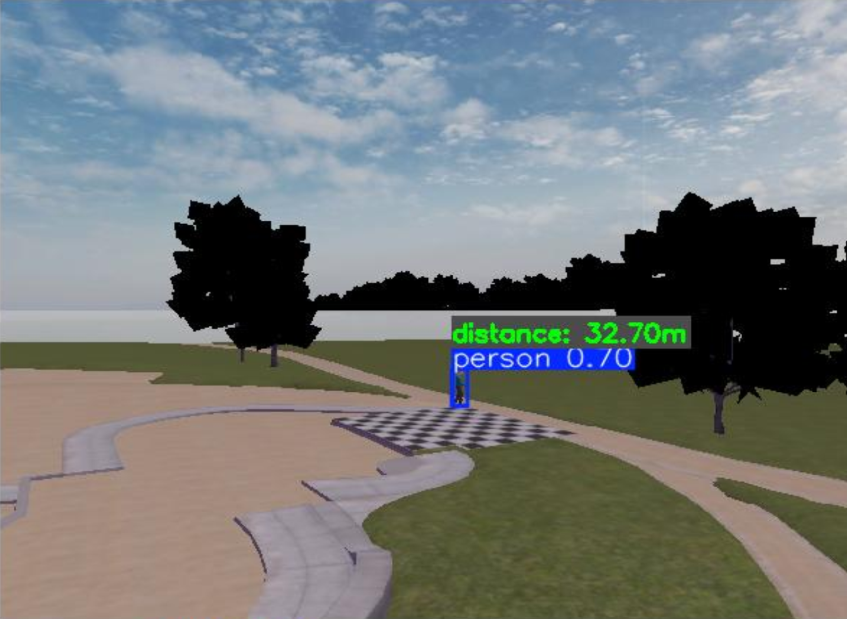
The project focuses on the development of an Unmanned Aerial Vehicle (UAV) application designed for manual keyboard-controlled navigation, real-time Simultaneous Localization and Mapping (SLAM) utilizing RTAB-Map (Real-Time Appearance-Based Mapping), and advanced computer vision-based human detection using YOLO.
Purpose
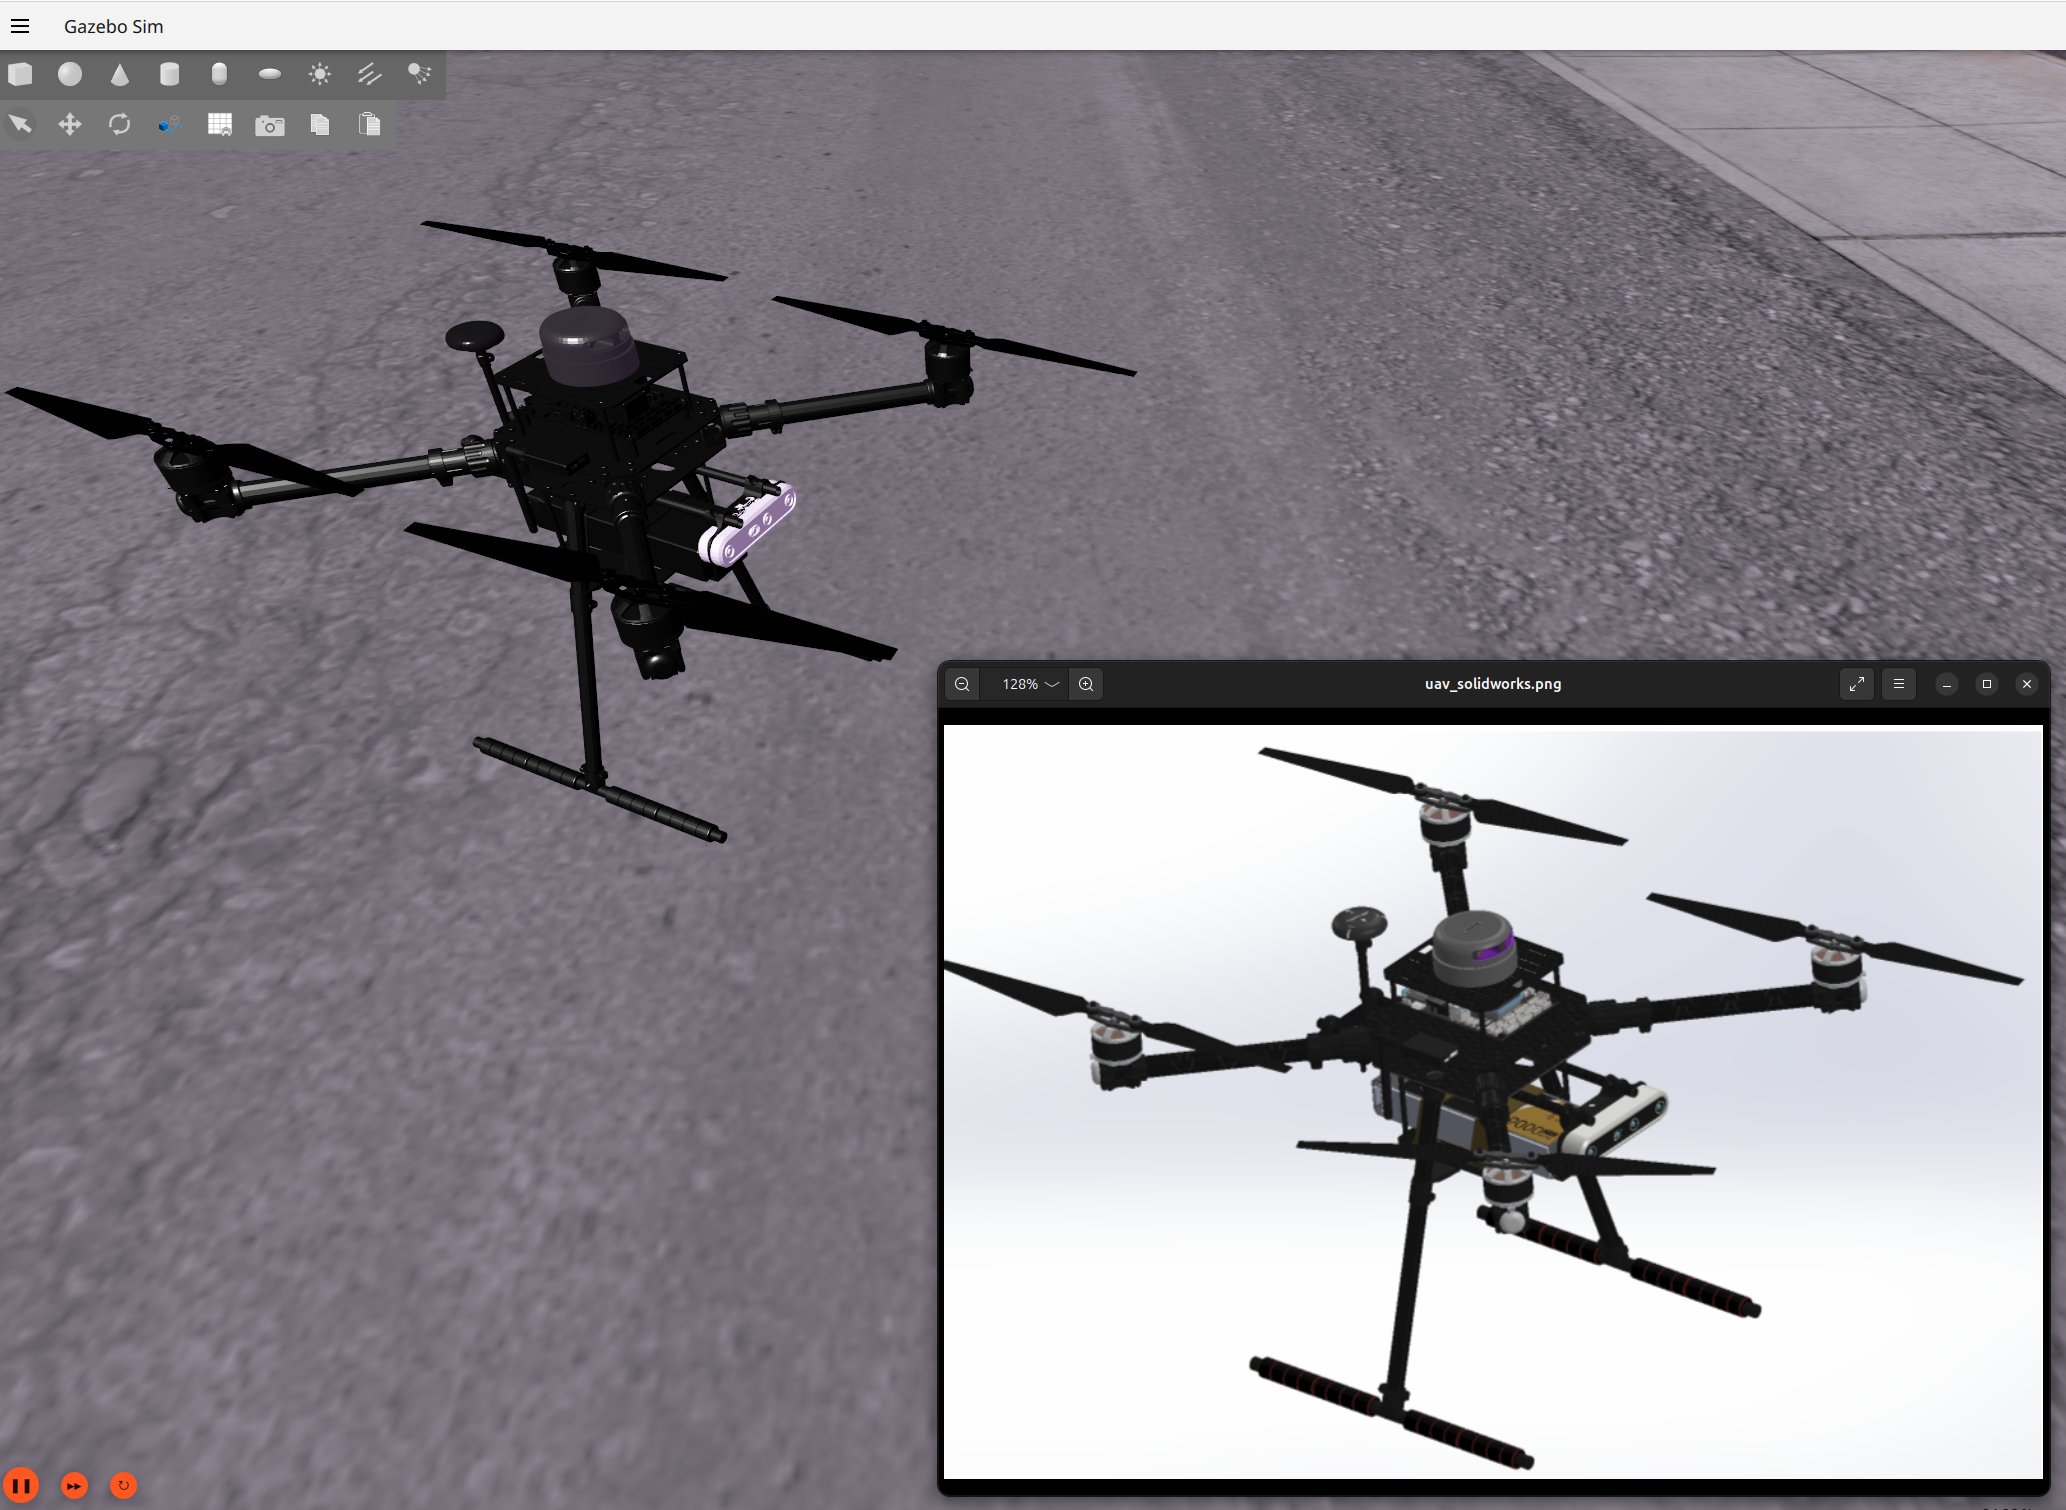
By leveraging custom CAD digital modeling, modern robotics frameworks, and artificial intelligence, this system establishes a scalable platform suitable for complex, large-scale missions such as surveillance, mapping, and search-and-rescue operations. Full technical documentation and architectural details are available in the Master’s Thesis (currently available in Greek).
Development
| System | Ubuntu 24.04 LTS (Noble Numbat) |
| IDE & Tools | Visual Studio 2013, Qt Creator |
| Programming Languages | C++ (Low-level performance/development), Python (High-level script orchestration) |
| Robotics Framework | ROS 2 (Jazzy Jalisco) |
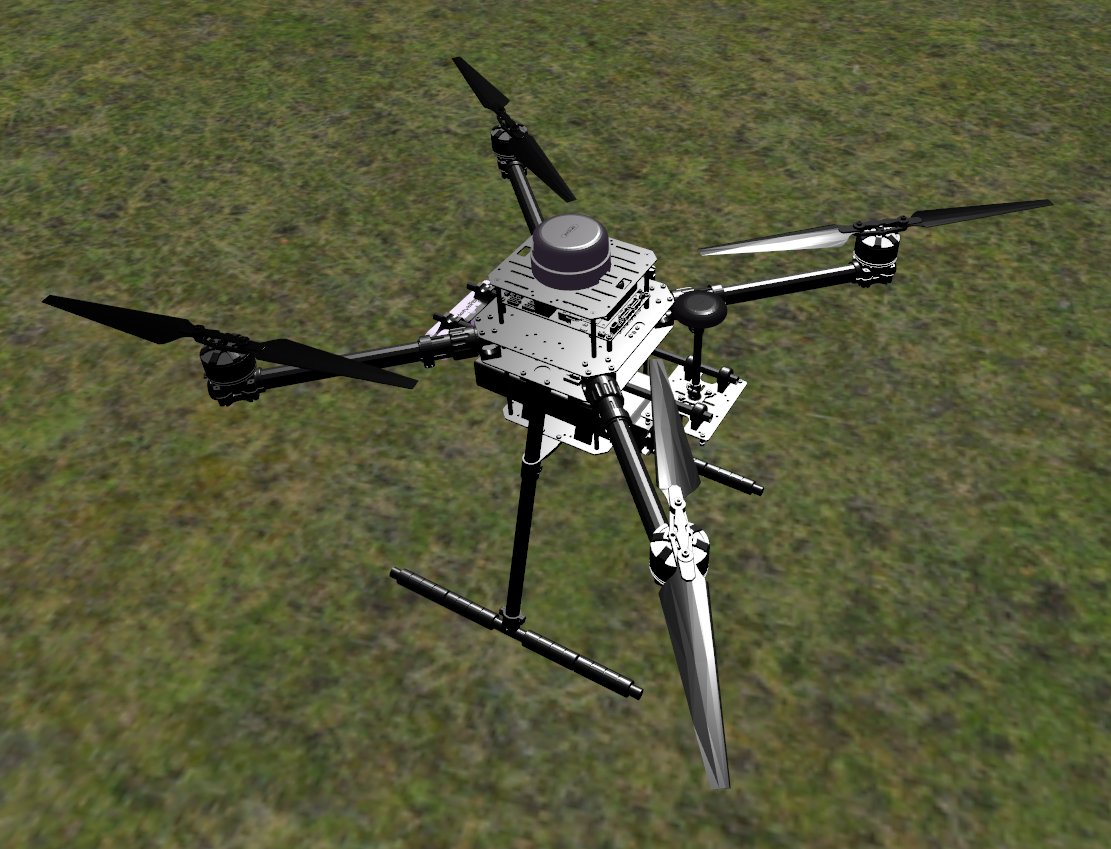
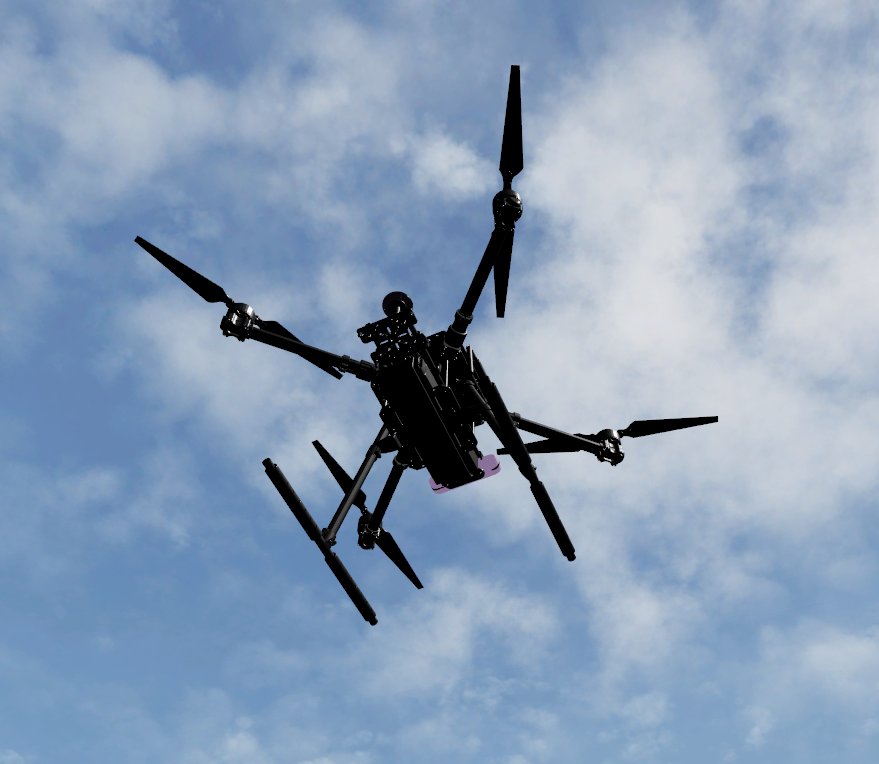
| UAV Modeling | SolidWorks with URDF Exporter plugin (URDF & STL generation) |
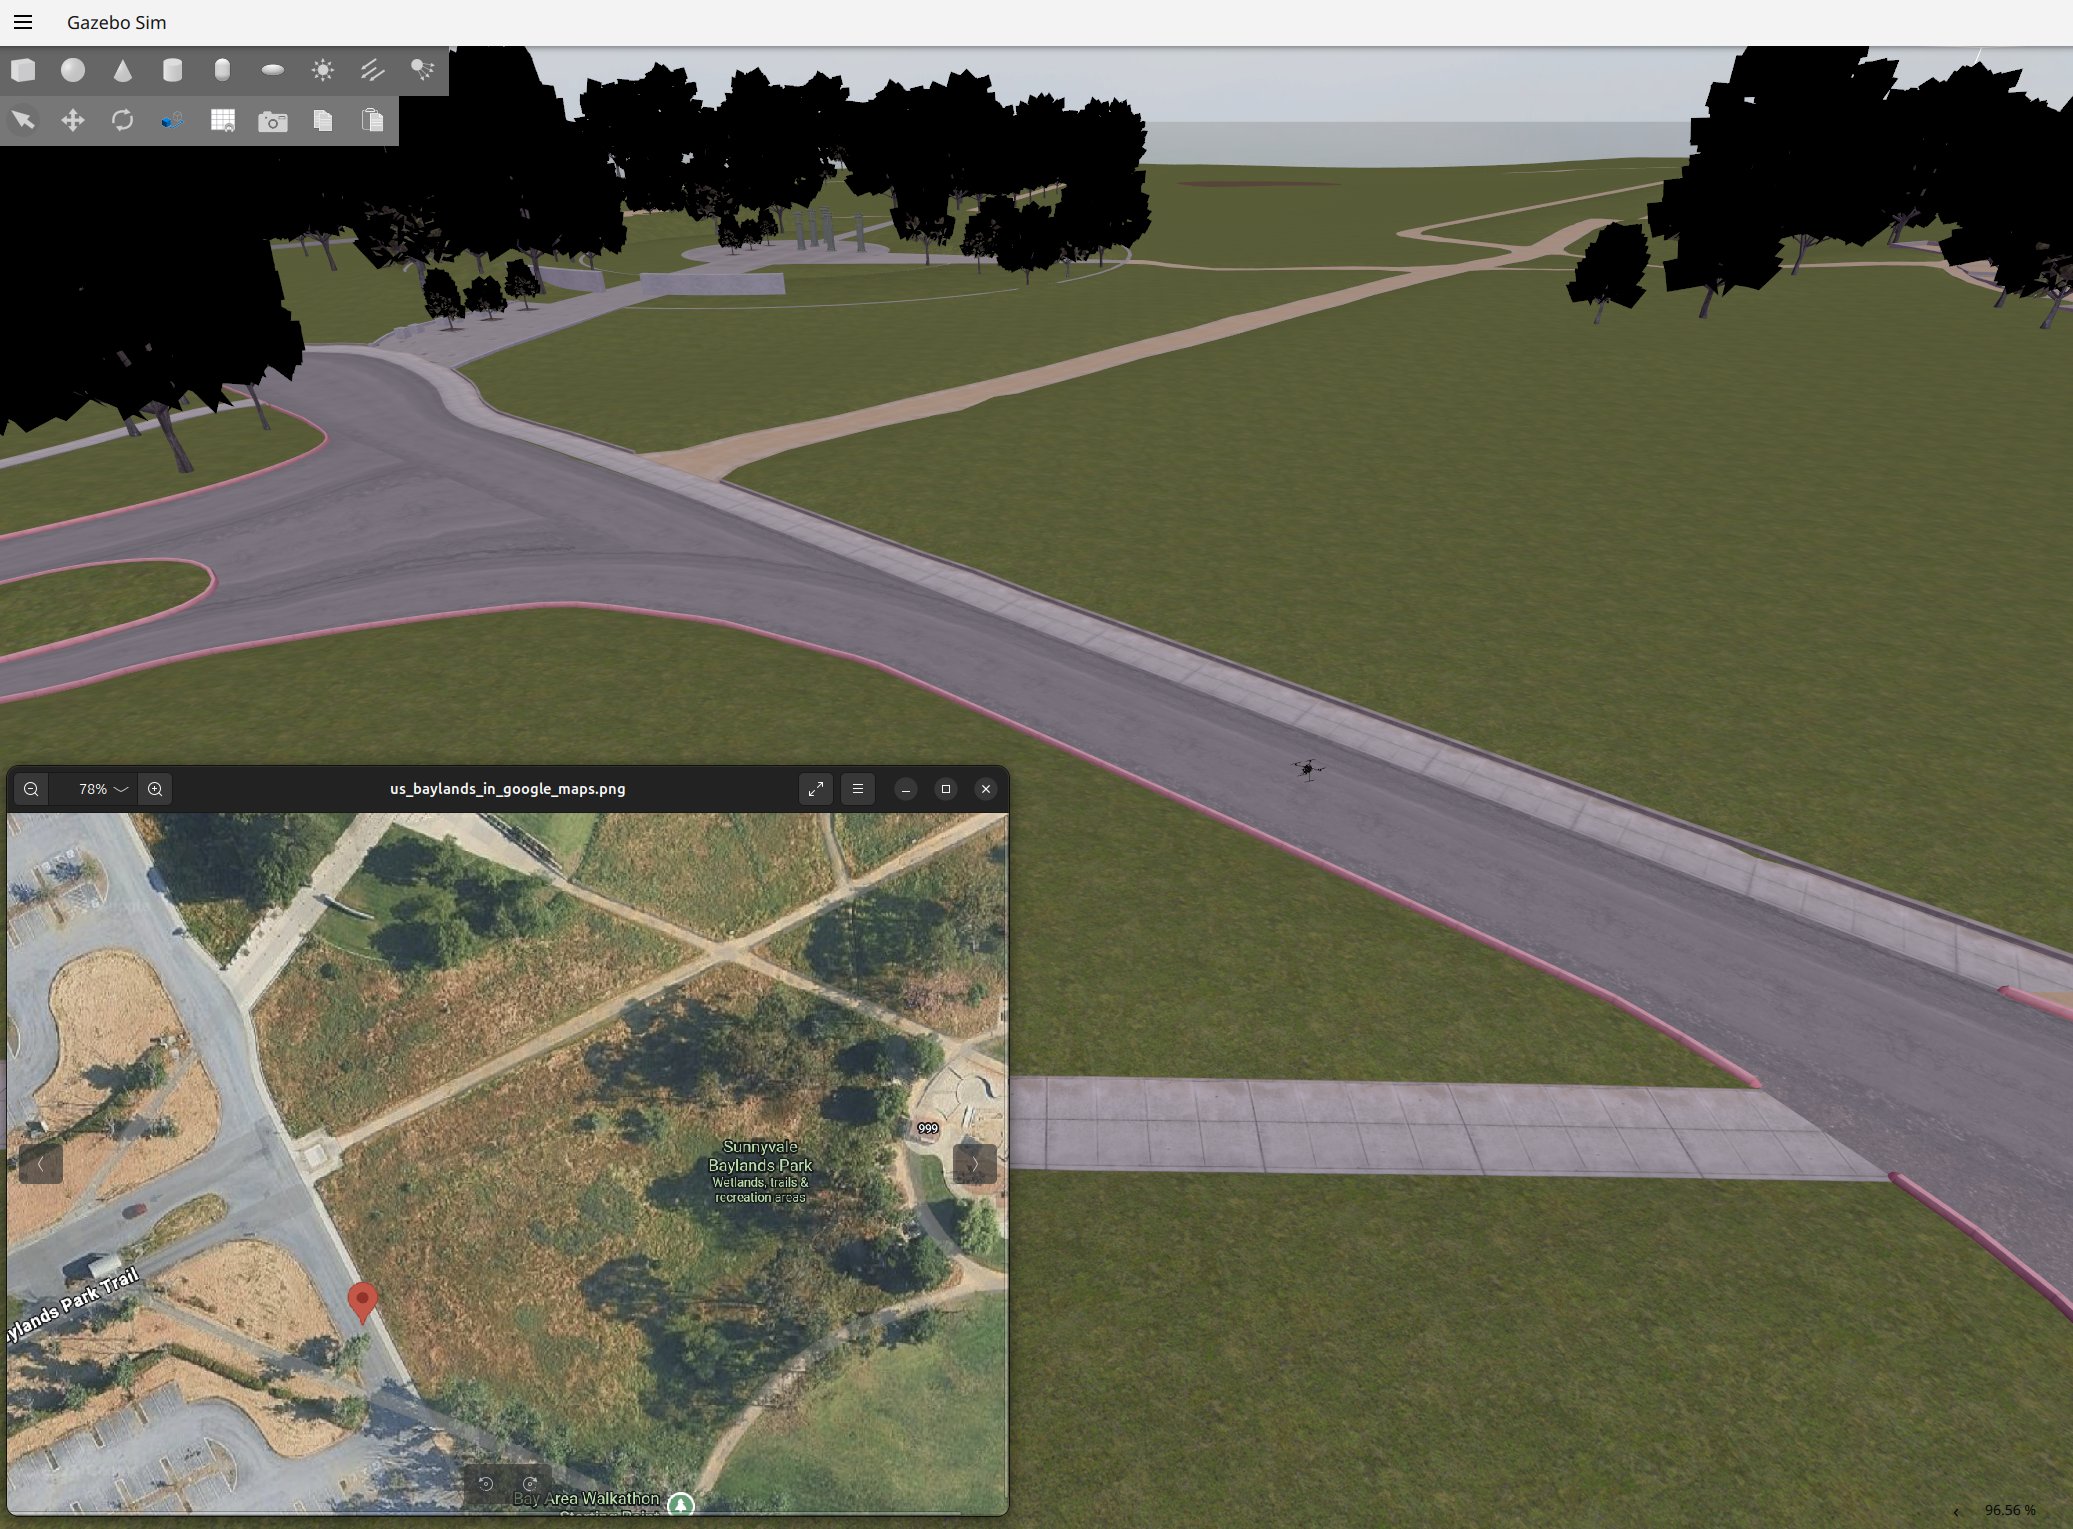
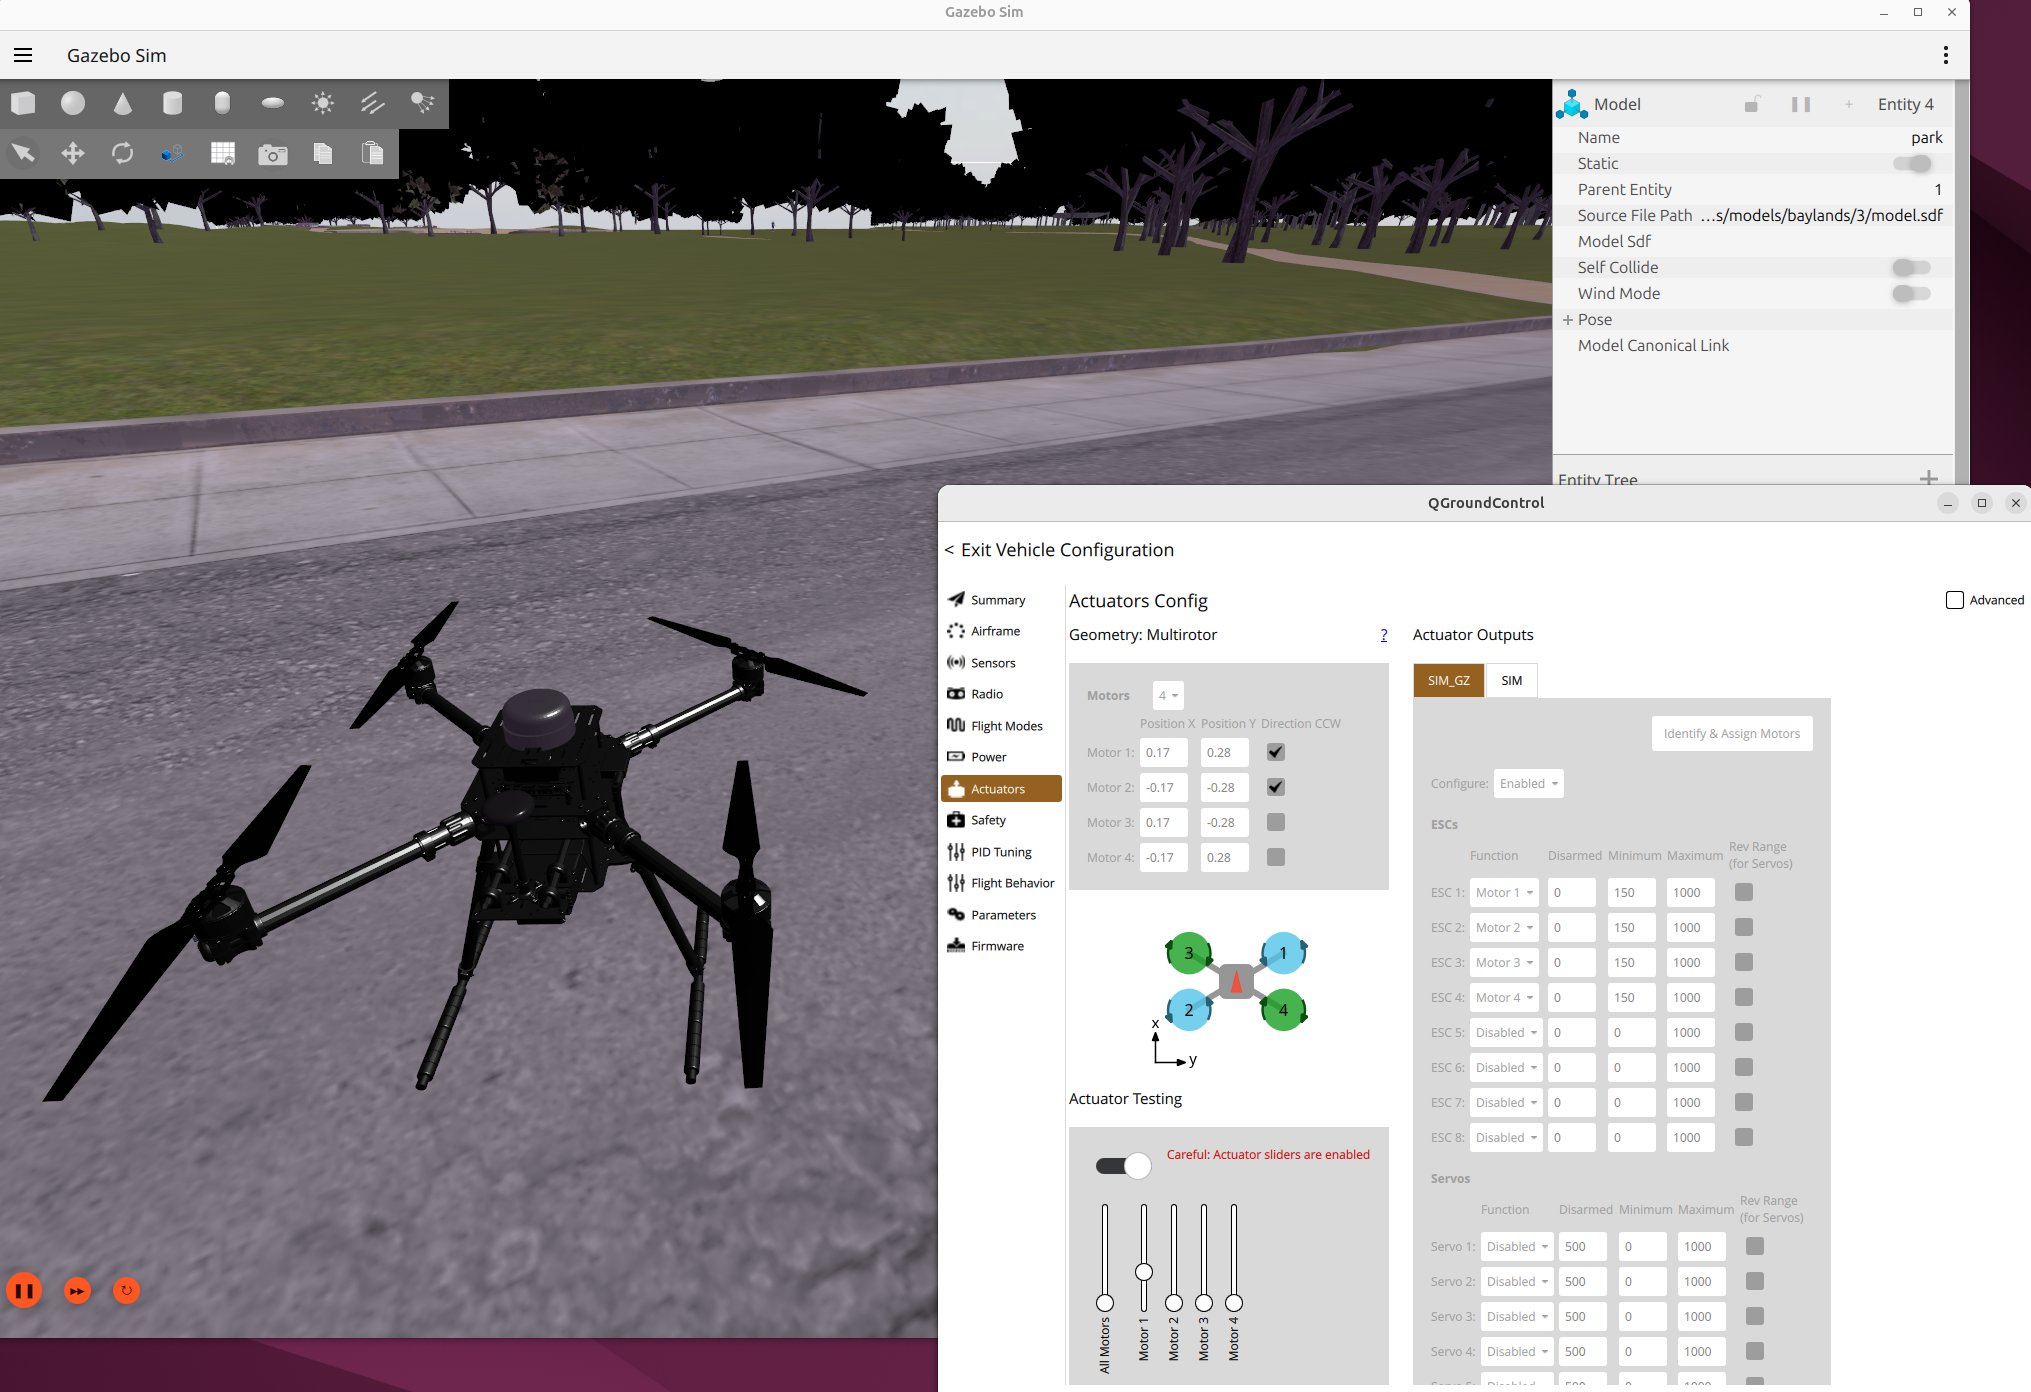
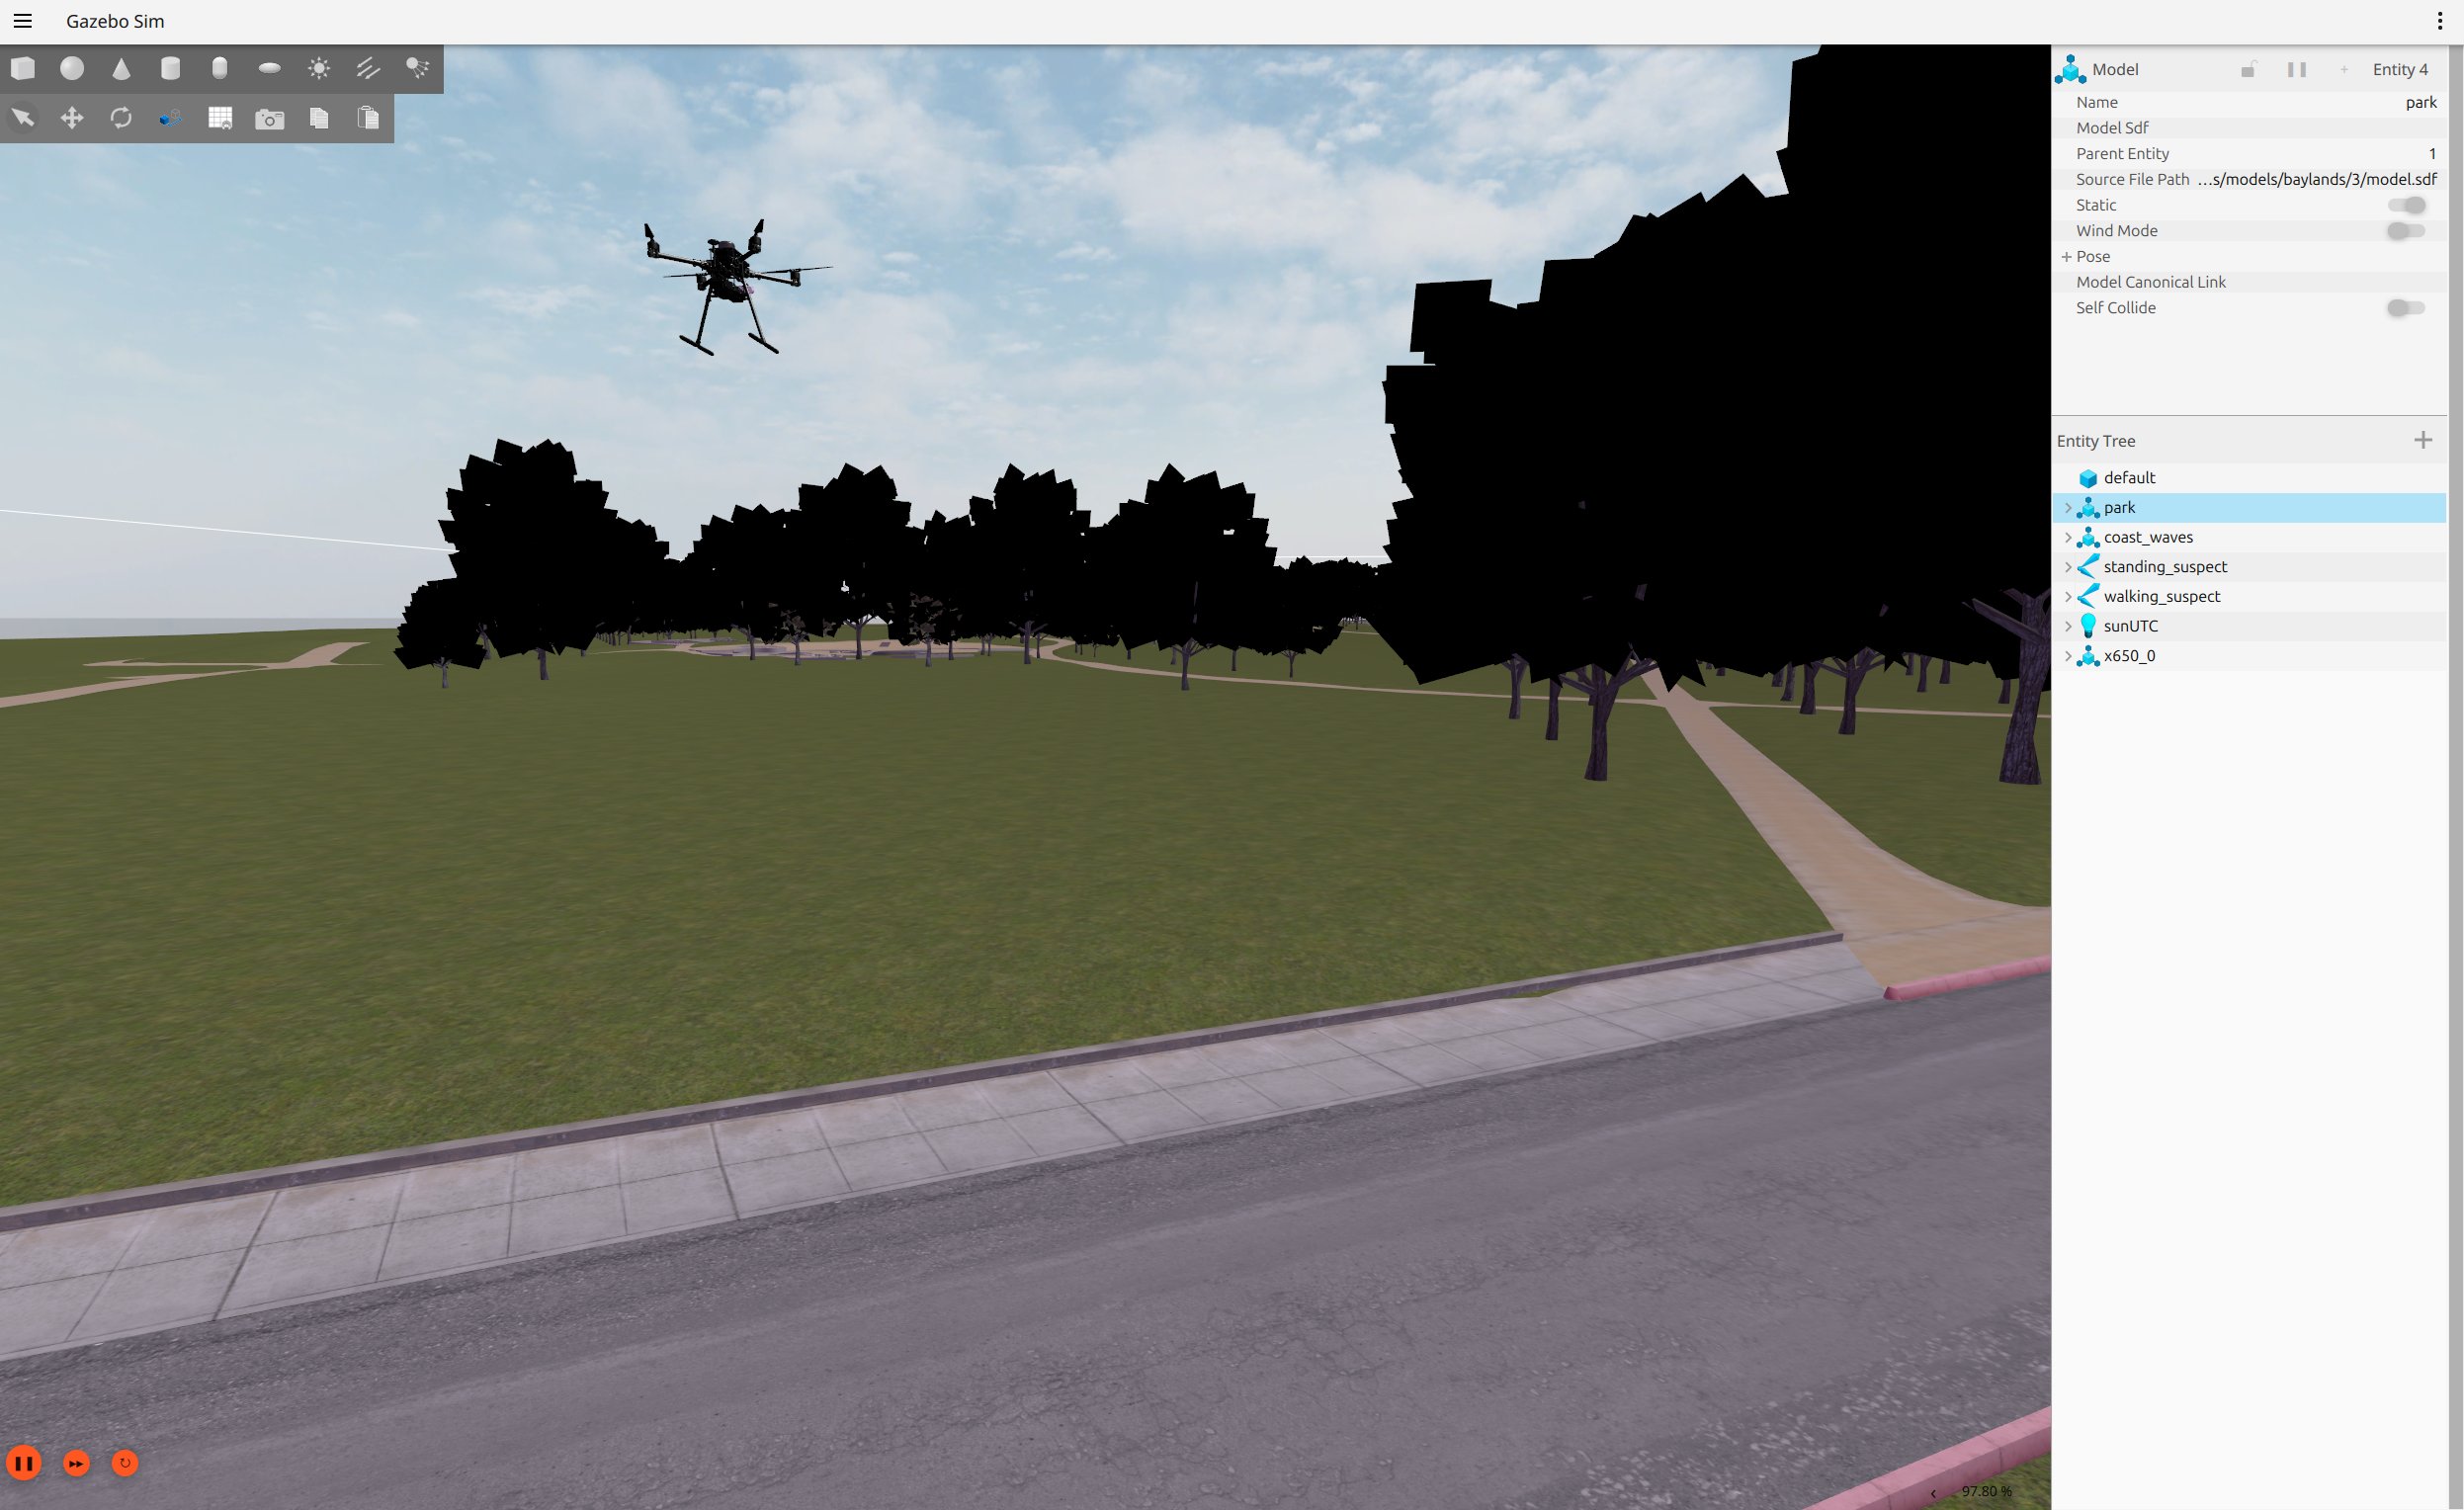
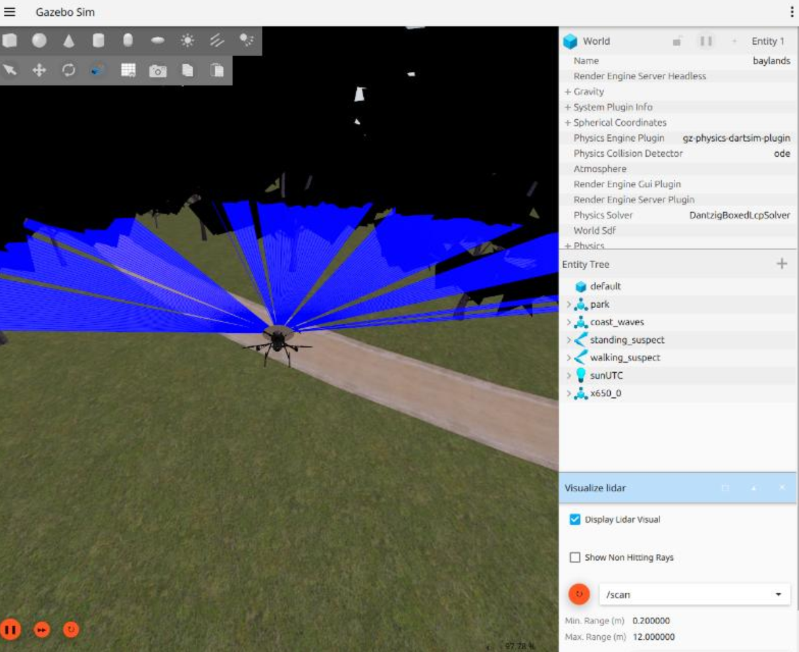
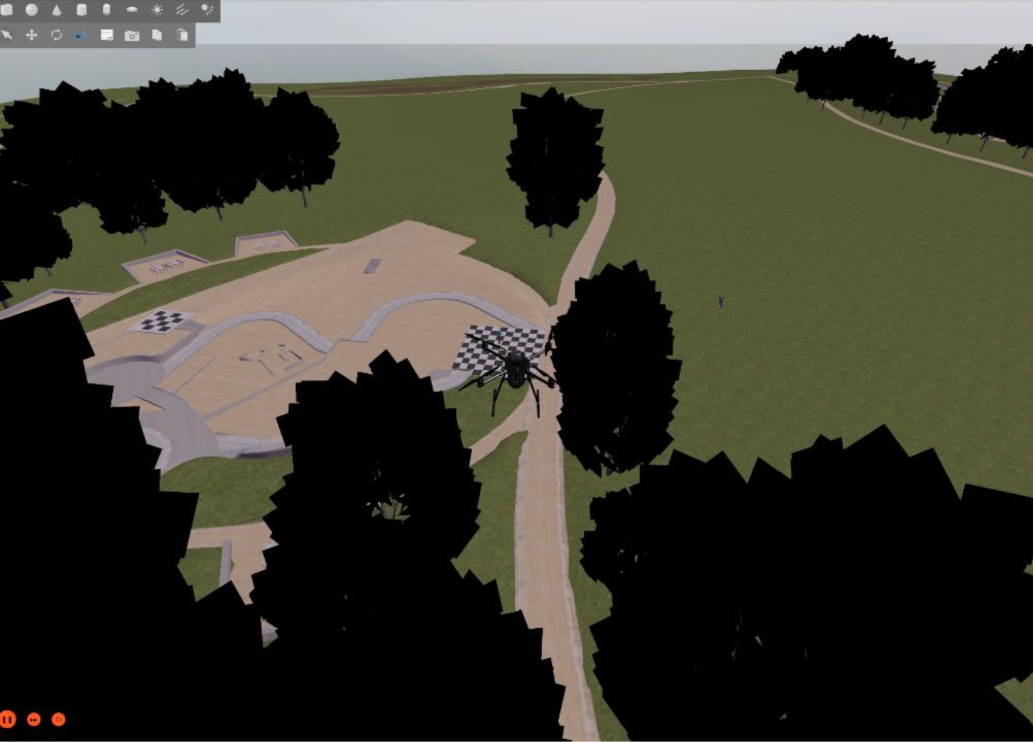
| Simulation | Gazebo (Harmonic), RViz |
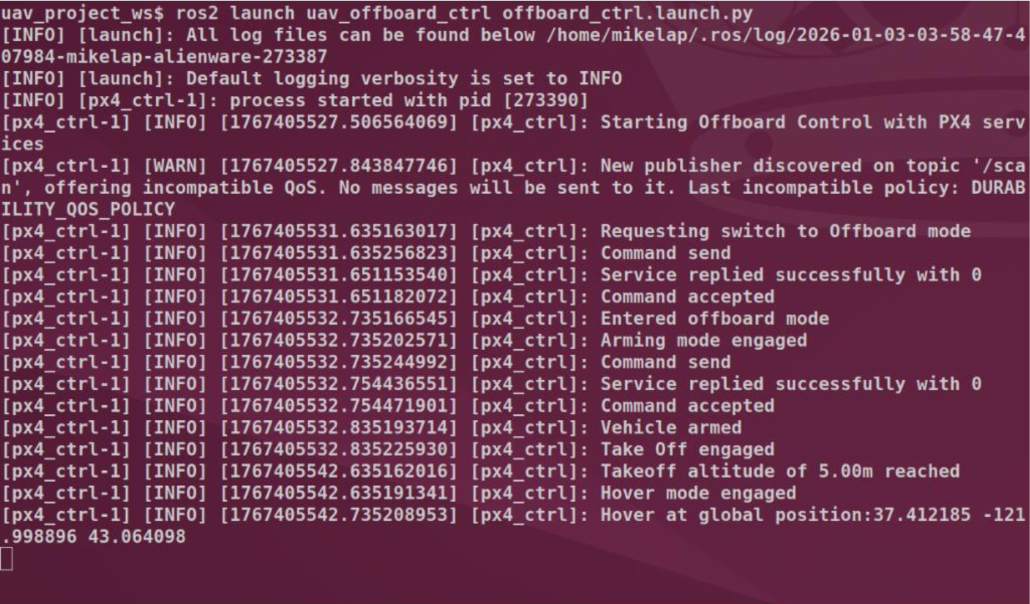
| Flight Control Stack | PX4 Autopilot Stack |
| SLAM Package | RTAB-Map (Real-Time Appearance-Based Mapping) |
| Computer Vision Packages | OpenCV, YOLO (You Only Look Once) |
| Ground Control & Telemetry | QGroundControl (Real-time flight operation management) |
| Repository |  |
Screenshots